
HIL2 min read
Peking University and PrimeBot's HIL-UMI Collects Robot Correction Data Without a Robot Arm
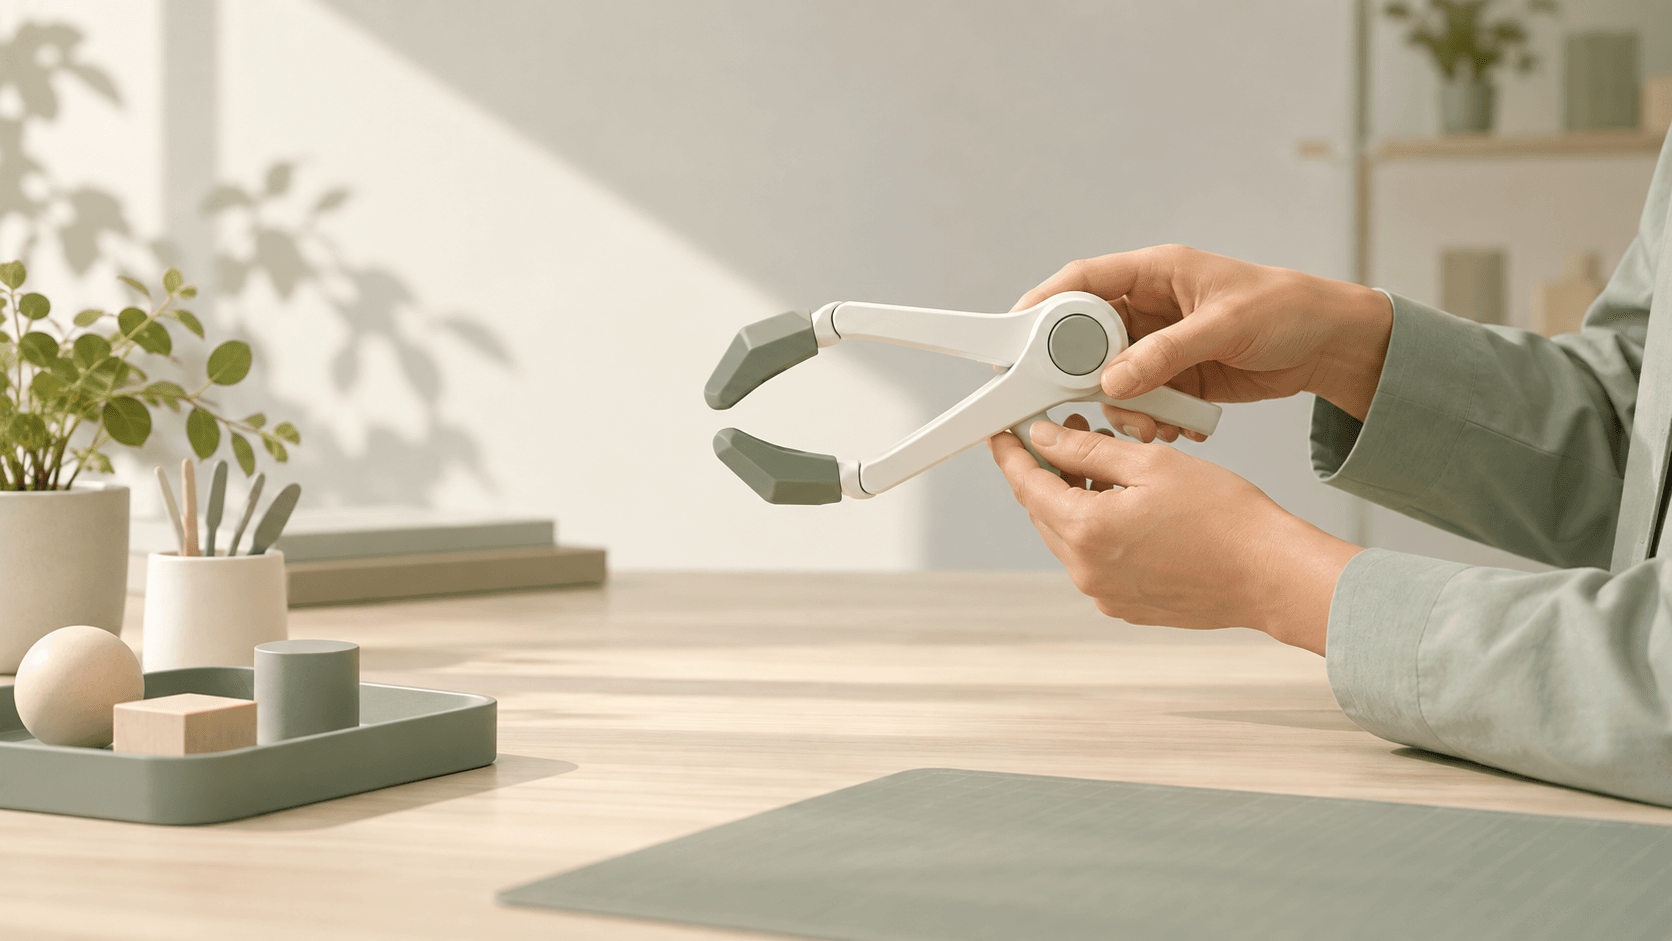
Peking University and PrimeBot's HIL-UMI uses a handheld gripper to collect robot correction data when a policy disagrees with a human demo. The team claims about 5.6x efficiency versus HG-DAgger.


By PandailyPandaily
Read the full story
Originally published by Pandaily on Oct 21, 2026.
Comments
Sign in to join the discussion.