
Spranic builds spatial memory for physical AI
Physical AI needs context about its surroundings to adapt beyond a fixed set of instructions. Munich-based Spranic is building a spatial memory layer that records physical spaces and how they change.
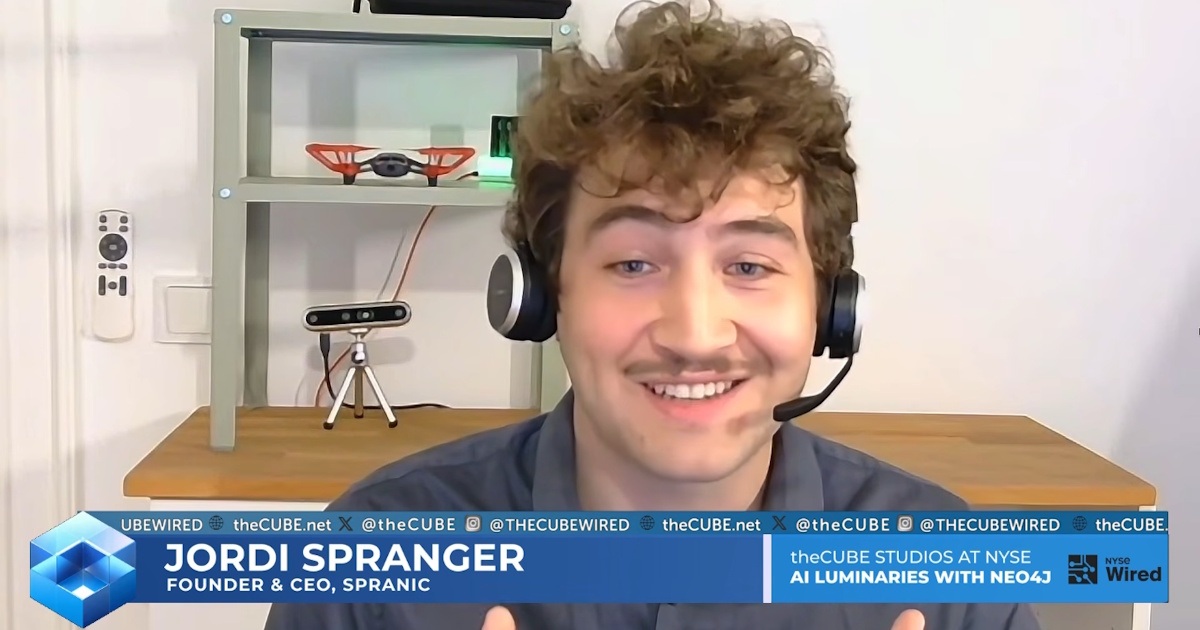
Spranic is developing a spatial memory layer for physical AI, enabling robots to adapt to changing environments by recording and interpreting physical spaces.
What happened
Spranic, a Munich-based company, is developing a spatial memory layer for physical AI that records and interprets physical spaces. This technology connects with knowledge graphs to help robots adapt to different tasks and environments, making their decisions auditable. The company's founder, Jordi Spranger, emphasizes the importance of reusable spatial context and flexible data sources for robots to operate safely and effectively.
Why it matters
This development is significant for AI developers and robotics engineers as it enables robots to adapt to dynamic environments, reducing the need for static task planning. It also enhances the safety and audibility of robotic operations, which is crucial for real-world applications.
- Spranic's spatial memory layer helps robots adapt to changing environments by providing contextual information.
- Knowledge graphs are essential for connecting data sources and ensuring auditable decision-making in robotics.
- Reusable spatial context reduces the need for task-specific planning in robot deployments.
- Provenance tracking ensures data reliability and enhances the safety of AI operations.
The bigger picture
The integration of spatial memory and knowledge graphs can significantly enhance the adaptability and safety of physical AI systems, enabling them to operate across diverse scenarios with greater flexibility and reliability.
Spranic's spatial memory layer for physical AI represents a significant advancement in enabling robots to adapt to dynamic environments, making their operations more flexible, safe, and auditable.
Technical details
- Spatial memory layer for physical AI
- Knowledge graphs for connecting data sources and preserving provenance
- Integration of spatial data with contextual information for adaptive decision-making
- Use of provenance tracking to ensure data origin and reliability
FAQ
What is Spranic's spatial memory layer?
Spranic's spatial memory layer is a technology that records and interprets physical spaces, providing context for physical AI to adapt beyond fixed instructions.
How do knowledge graphs help robots?
Knowledge graphs help robots interpret environments across tasks, make decisions auditable, and connect relevant data sources while preserving provenance.
Why is reusable spatial context important for robots?
Reusable spatial context reduces the need for task-specific planning, allowing robots to operate more flexibly and efficiently in changing environments.
What role does provenance play in Spranic's approach?
Provenance ensures that the data used to inform a robot's actions is traceable and reliable, enhancing the safety and audibility of AI operations.
What are the benefits of integrating spatial memory with knowledge graphs?
Integrating spatial memory with knowledge graphs enhances adaptability, flexibility, and safety in robotic operations by enabling context-aware decision-making and data source management.
This summary and analysis were generated with AI from the original article and may contain errors. Read the original for the full story.
Read the full story
Originally published by SiliconANGLE on Oct 13, 2026.
Comments
Sign in to join the discussion.