
Build a Robot Pick-and-Place Simulation with SimReady Assets
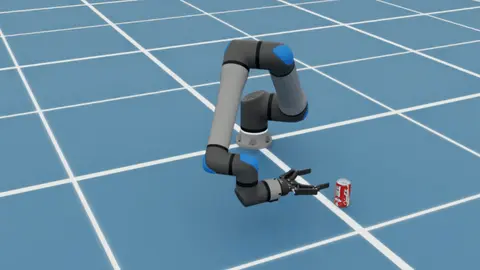
This walkthrough showcases a beverage can pick-and-place task that uses the UR17G arm, Robotiq 2F-140 gripper, and beverage can to compose a scene in Isaac Sim, check their behavior, and run a pick-and-place example with agent-generated controls.
Hugging Face Blog9 min read